Download
The dataset is published on zenodo. Click [Dataset] to get there.
The dataset is provided in a unified HDF5 format, including:
- Wrench (Force/Torque): 3-axis force, 3-axis torque sampled.
- Robot State: 6-DOF joint positions, velocities and efforts.
- End-Effector Pose: 6-DOF Cartesian poses (position + quaternion).
- Vision: RGB and Depth images.
The dataset structure is as follows:
- /wrench/data: [N, 6] array of forces and torques
- /wrench/timestamps: [N] array of aligned timestamps
- /pose/data: [M, 7] array of cartesian poses
- /pose/timestamps [M] array of aligned timestamps
- /joint_states/data: [M, 3, 6] array of joint states
- /joint_states/timestamps [M] array of aligned timestamps
- /rgb/data: [K, H, W, 3] rgb image stream
- /rgb/timestamps: [K] array of aligned timestamps
- /depth/data: [K, H, W, 3] depth image stream
- /depth/timestamps: [K] array of aligned timestamps
Dataset contains five trial folders. Each trial folder consists of subfolders representing the assembly subtasks. In each subtask folder, the data of the executed movement and assembly primitives are saved as .h5 files:
trial_XY/subtaskname/timestamp_asm_subtaskname_primitivename.h5
Where trial_XY can be one of [trial_0, trial_1, trial_2, trial_3, trial_4].
Dataset preview
A preview of the dataset can be viewed using rerun in your browser. Click
[Open preview] or the following image to get there.
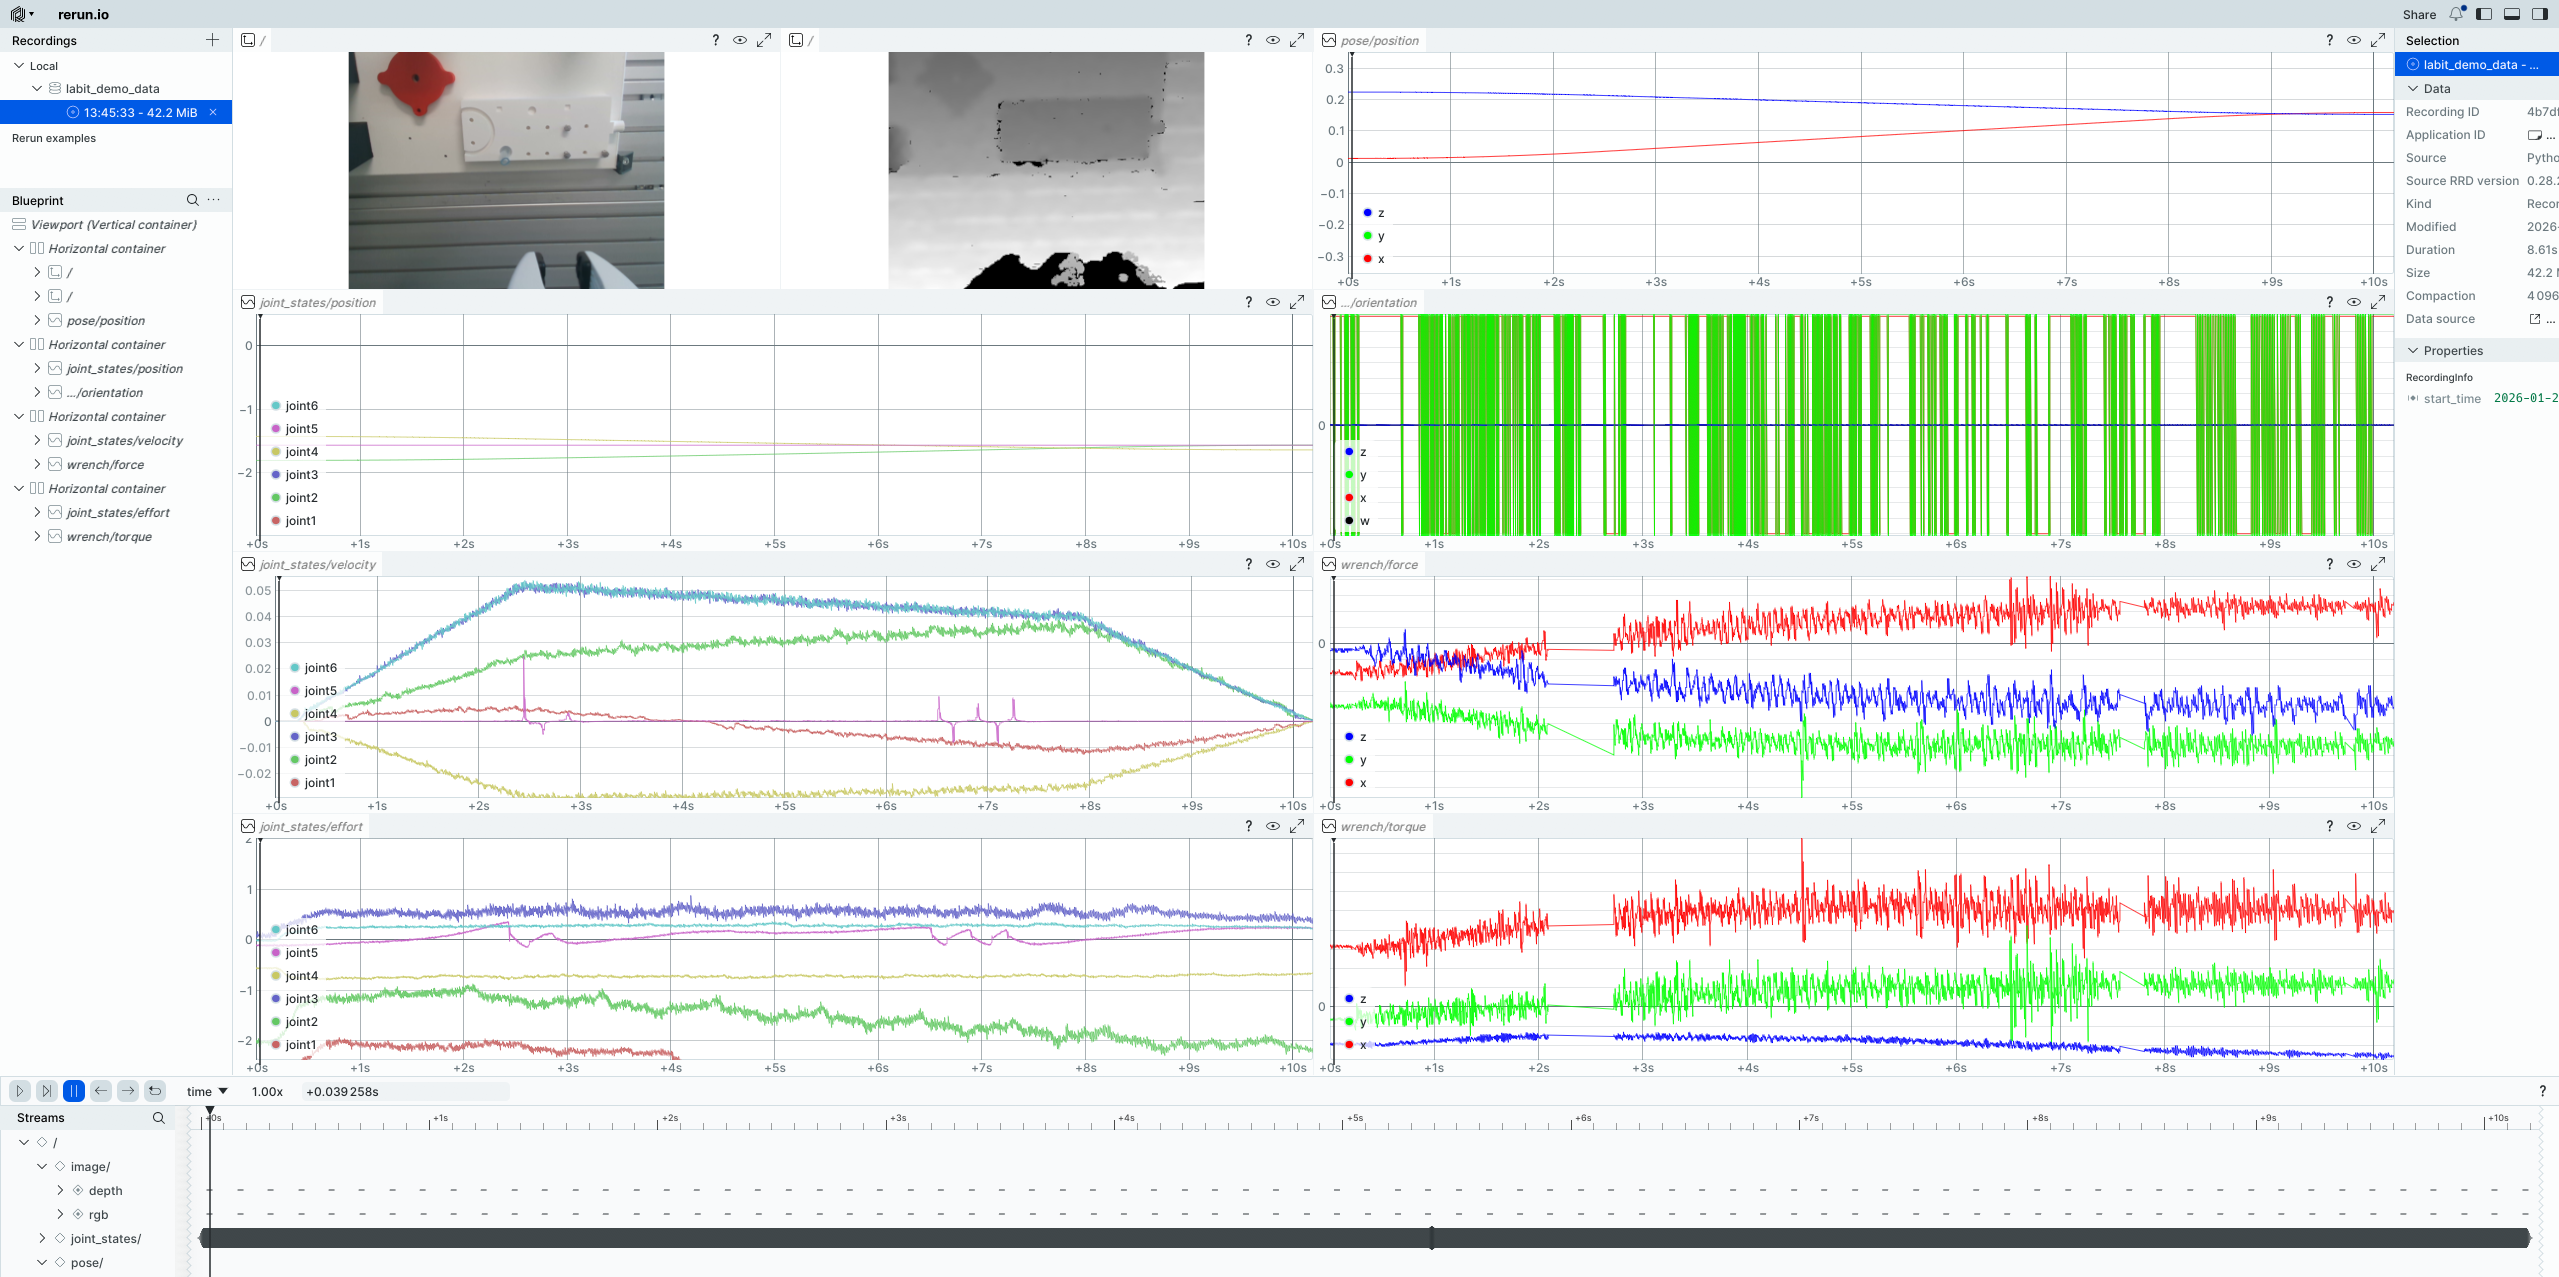
If there are problems with the data viewer, download the .rrd file manually from https://raw.githubusercontent.com/cschempp/robotic-assembly-benchmark/master/static/demo_data/labit_demo_data.rrd
and drag and drop it in the rerun preview window.